Each module in the Cross-Link Collective is about 200 millimeters long and 20 millimeters wide, and alone it moves slowly and inefficiently. Linked into chains, dozens of them form a robotic collective that flows, reshapes and keeps moving without any central controller. Engineers at Cornell built the system, and the work was published May 20 in Science Robotics.
How each module works
Every module holds a small motor that drives it to oscillate between two shapes, an "I" and a "U." The oscillation pushes against the ground, so the module inches forward and jostles into its neighbors. Weak Velcro patches at each end let modules latch onto one another and release again.
The group has no explicit computation or communication to coordinate it. Kirstin Petersen, the corresponding author, is an associate professor of electrical and computer engineering and the Aref and Manon Lahham Faculty Fellow in the Cornell Duffield College of Engineering. She describes the approach as moving intelligence into the robots' shape and physical interactions. The researchers call this mechanical intelligence. "We're leveraging the contact dynamics to let useful behaviors emerge, so the system naturally settles into configurations that reduce internal stresses and improve motion," Petersen said.
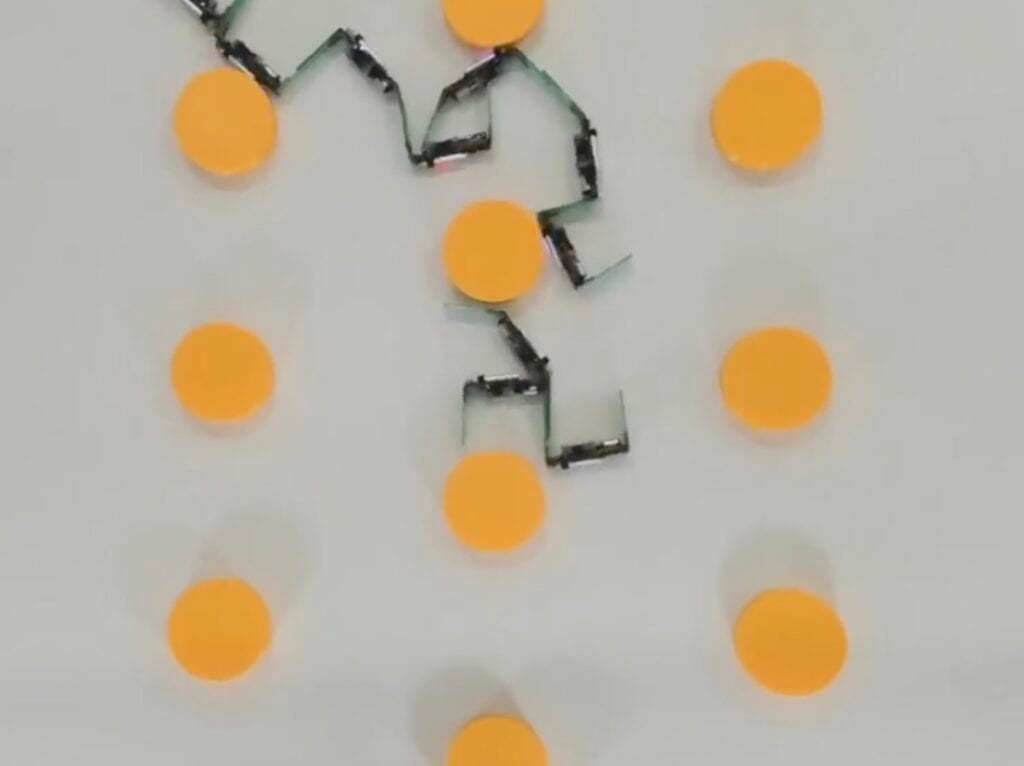
What happens when modules entangle
The behavior changes once modules entangle into chains. The chains begin to move collectively and self-organize into shifting configurations. The researchers describe the result as resilient in challenging environments.
On inclined surfaces, chains moved more reliably than individual modules. Individual modules often stalled, depending on their orientation. In obstacle fields, the collective behaved like a flowing material. Connections formed to maintain cohesion, then broke apart to prevent jamming. The system continuously deforms and reorganizes as it moves, which is why the team compares it to soft matter.
Lead author Danna Ma, a visiting lecturer in electrical and computer engineering, said the design tolerates failure. "It doesn't matter if one module has a compromised battery or fails for other reasons," she said. "The system stays functional because it can adapt. It is redundant and doesn't depend on any single module."
A small amount of computation
The team did not rule out computation entirely. They showed that a small amount can improve the collective's properties. To keep the group cohesive, a module that has become isolated emits an audible distress signal. Nearby modules respond by slowing down, which gives the straggler time to reconnect.
Ma said there is no centralized sensing or control. Each module infers that it has lost contact with the group from how much it is being jostled. It then uses an audible buzz to slow nearby modules while it catches up.
Design history
Co-authors at the Georgia Institute of Technology developed the original module design. Petersen and Ma then refined it over years of experimentation and statistical analysis. The goal was to improve how well the modules entangle and operate in large numbers. The process showed that subtle changes in module size and other characteristics can influence how effectively the modules connect and move as a group.
The design draws on active gels, materials whose molecular links continually form and dissolve while the overall structure holds. The researchers say the findings could help inspire new forms of soft-matter engineering. They mostly see the system as a tool for studying how mechanical intelligence can produce resilient emergent behavior in robot collectives.
Why it matters, and what is not yet shown
The main contribution is a demonstration that useful group behavior can come from geometry and contact rather than from software. Most multirobot work assumes each unit senses, computes and communicates. Here the base behavior needs none of those, and the only added logic is a buzz triggered by jostling. That makes the failure model simple. Because no module is special, losing one removes a little capacity and nothing else. The source states this redundancy directly, and it follows from the absence of a central controller.
The result also suggests a way to think about reconfigurable and modular systems. Many modular designs rely on units that attach firmly and then follow a planned shape. This system takes the opposite approach. Its attachments are deliberately weak and temporary, and the group's shape is never specified. The reported benefit is that connections break before they cause jams. That is a trade of exact control for adaptability, which Petersen herself describes as giving up control over configurations and coordination to gain a range of useful behaviors.
Several questions remain open. The source gives no speeds, energy figures or payload capacity, so the efficiency of the collective compared with the individual modules is not quantified here. It reports tests on inclines and in obstacle fields, but it does not describe operation outside those controlled settings. It also does not say how the approach scales beyond dozens of modules, or how well weak Velcro holds up with dirt, moisture or repeated cycles. Those limits matter for any real-world use.
The researchers themselves are cautious about applications. They frame the system mainly as a platform for studying emergent behavior, with soft-matter engineering as a possible downstream influence. That is a reasonable reading of the evidence so far. The work shows that a physically simple robotic collective can sustain coordinated motion and recover from member failure. It does not yet show that this design can perform a task people need done.