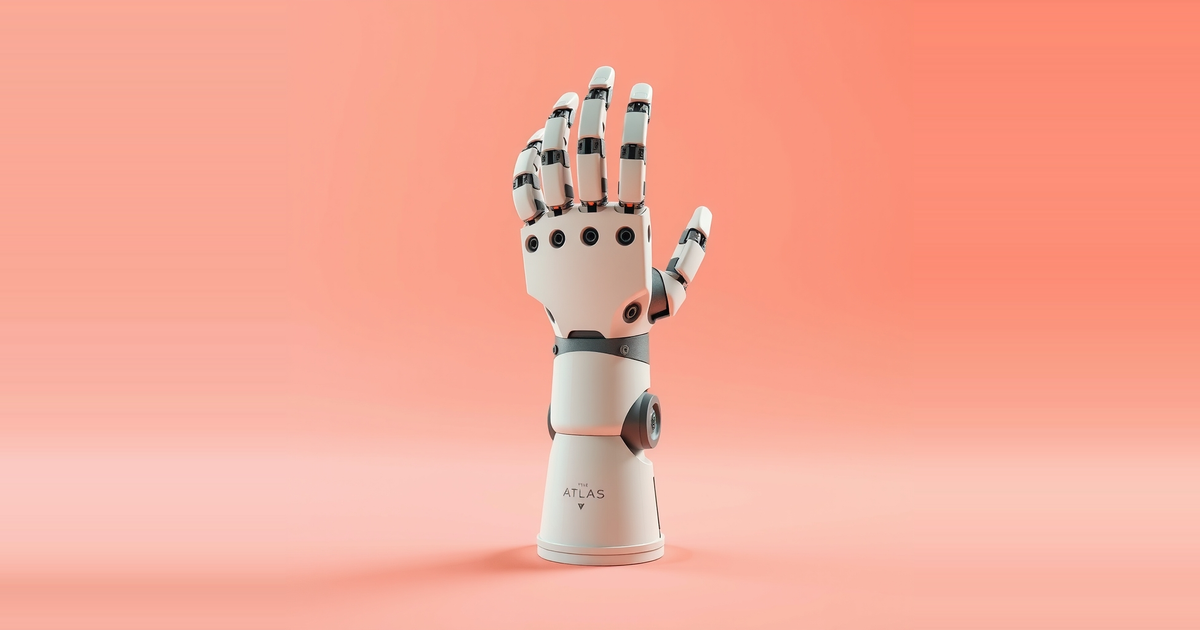
A new hand for the Atlas humanoid robot is drawing attention because it may work better than designs that copy the human hand. IEEE Spectrum reports on the development under the headline "Atlas Robot's New Hand May Outperform Humanlike Designs."
Humanoid developers have long debated how closely a robot hand should resemble a human one. Five-fingered, humanlike hands promise versatility in human-built environments, but they are mechanically complex and can be fragile. The Atlas hand points to a different approach: a design that is more robust and may handle real-world work better than a direct imitation of human anatomy.
The source summary does not give technical specifications, so details such as the finger count, grip strength, and payload are not covered here. The full report is available at IEEE Spectrum.
The story reflects a wider shift in humanoid robotics. Teams are focusing on durability and task performance rather than strict human likeness, especially as humanoids move toward practical deployment.